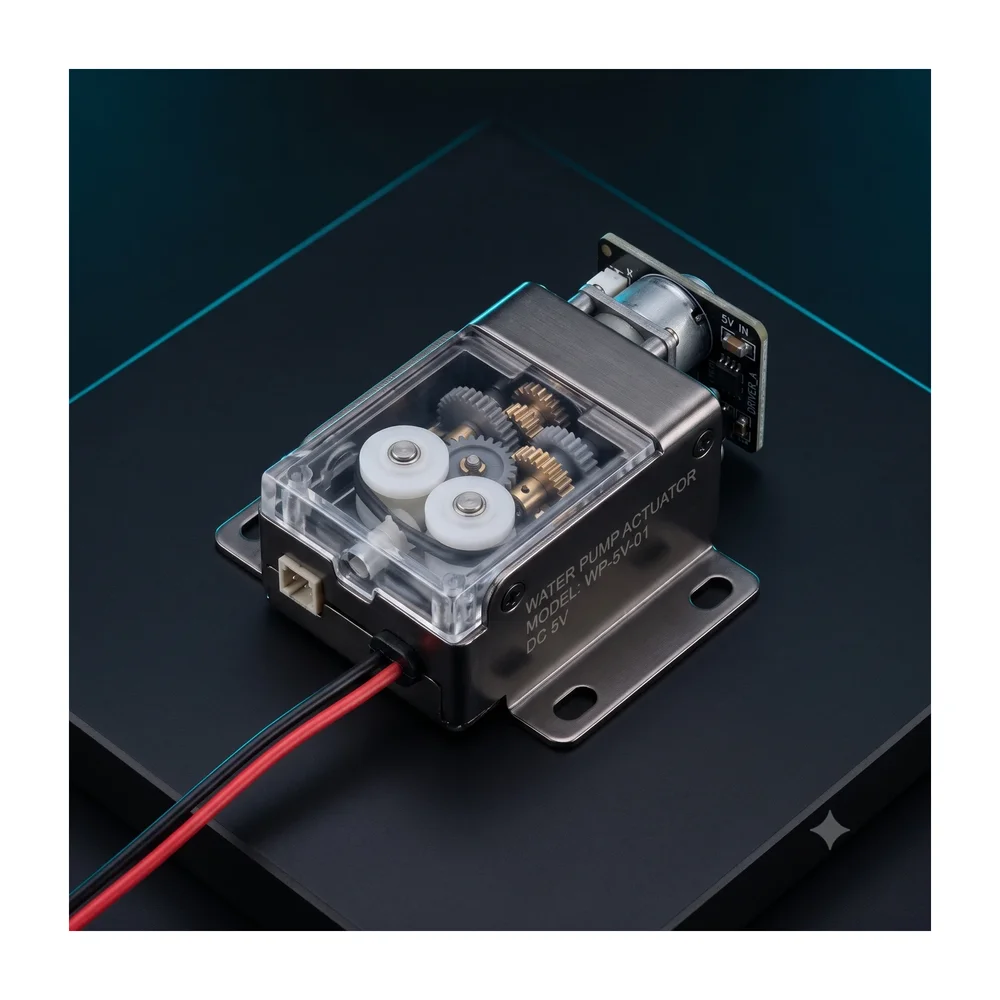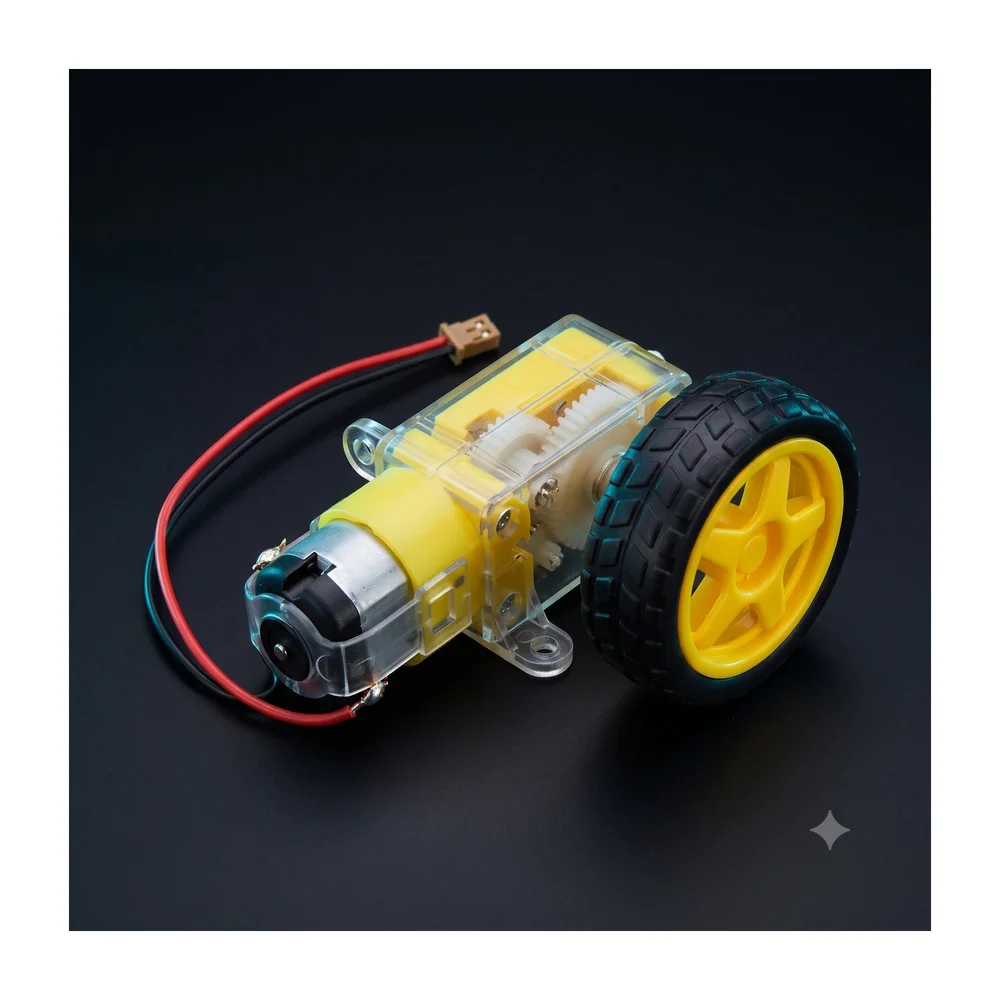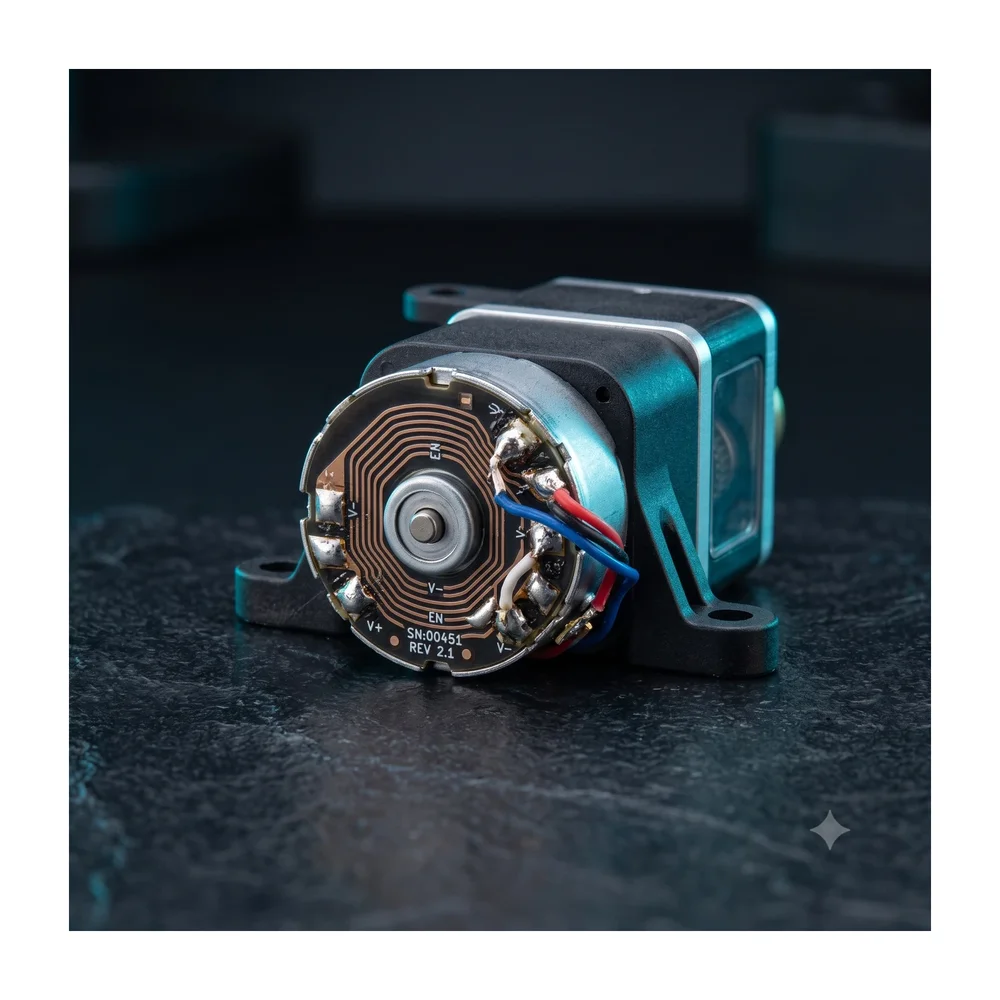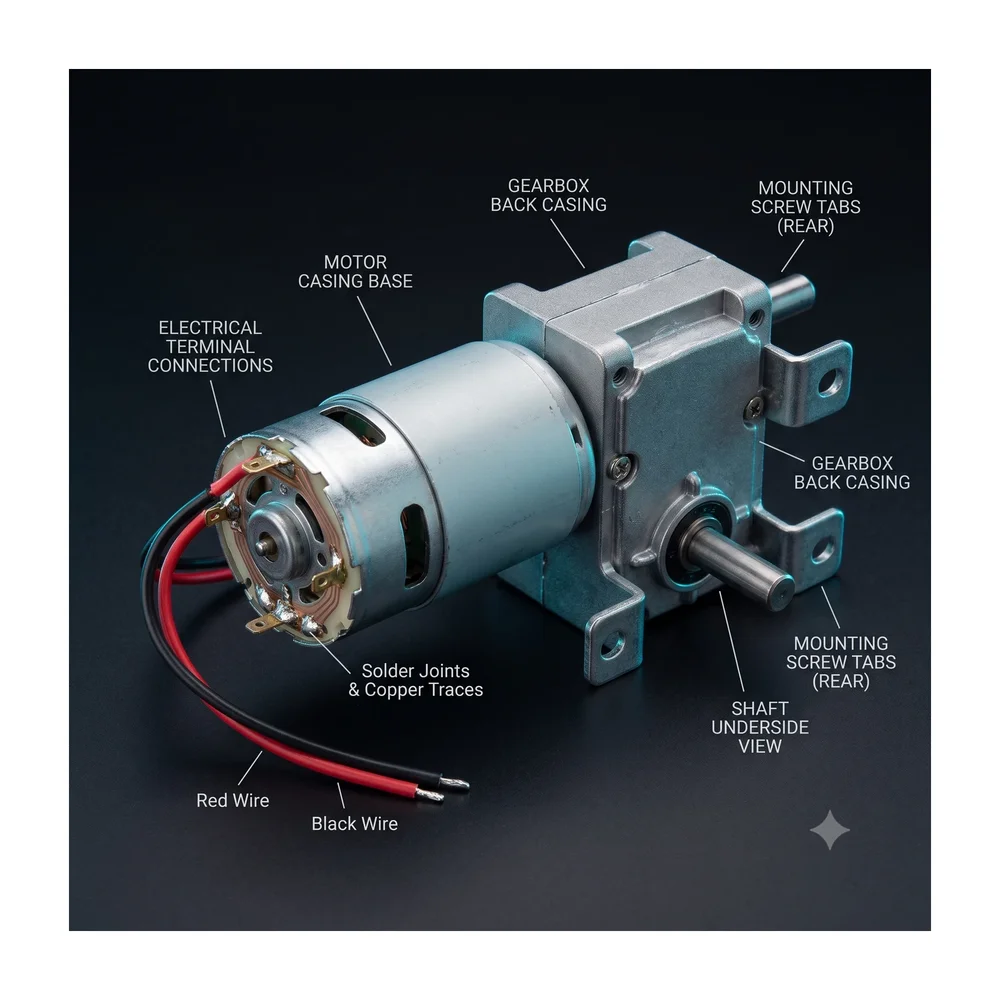
DC 12V 10RPM Metal Geared Motor
- •Product Name: DC 12V 10RPM Metal Geared Motor
- •Product Category: Motors & Actuators
- •Operating Voltage: 12V DC
- •Operating Temperature: -20°C to +65°C
- •Mounting Type: Through Hole / Screw Terminal / Modular
- •Efficiency / Accuracy: Up to 95%
- •Dimensions: Body Diameter: 38mm
- •Motor Length with shaft: 77 mm
Description
[Gear Motor] Specification: Weight: 125 gm(Approx.) RPM: 10 Operating Voltage: 12V DC Gearbox: Attached Metal Gearbox Shaft diameter: 6mm Shaft Length: 21 mm Torque: As per RPM No-load current = 60 mA(Max) Load current = 300 mA(Max). Dimensions: Body Diameter: 38mm; Motor Length with shaft: 77 mm; Same size motor available in various RPMs.
🔹 Key Features
- •Dimensions: Body Diameter: 38mm
- •Motor Length with shaft: 77 mm
- •Same size motor available in various RPMs
🔹 Technical Specifications
🔹 Pin Configuration & Wiring
⚠️ Direct MCU GPIO Connection Hazard
DC 12V 10RPM Metal Geared Motor is an inductive electro-mechanical load drawing up to 200mA – 1A+ surge current. An ESP32 GPIO pin is rated for only 12mA (Arduino Uno is rated for 20mA).
Never wire this motor directly to ESP32 / Arduino pins. Doing so will immediately destroy the microcontroller's output transistors due to inrush current and reverse back-EMF inductive voltage spikes. Always use an intermediate motor driver or transistor switch with a common ground.
Recommended Driver & Interfacing Architectures
Select your interfacing method to inspect the exact wiring diagram & code
Connection Matrix
// Safe Motor & Air Pump PWM Speed Control using L298N Driver
// Tested for Arduino Uno & ESP32 (with ESP32 ledcWrite)

#define ENA_PIN 9   // Connect to L298N ENA (PWM speed control)
#define IN1_PIN 8   // Connect to L298N IN1 (Direction / ON)
#define IN2_PIN 7   // Connect to L298N IN2 (Direction / OFF)

void setup() {
  pinMode(ENA_PIN, OUTPUT);
  pinMode(IN1_PIN, OUTPUT);
  pinMode(IN2_PIN, OUTPUT);

  // Initialize driver in OFF state
  digitalWrite(IN1_PIN, LOW);
  digitalWrite(IN2_PIN, LOW);
  analogWrite(ENA_PIN, 0);
}

void loop() {
  // Soft start: ramp up speed to prevent inrush current spikes
  digitalWrite(IN1_PIN, HIGH);
  digitalWrite(IN2_PIN, LOW);

  for (int speed = 100; speed <= 255; speed += 15) {
    analogWrite(ENA_PIN, speed);
    delay(50);
  }

  delay(3000); // Run motor at full speed for 3 seconds

  // Coast to stop
  digitalWrite(IN1_PIN, LOW);
  digitalWrite(IN2_PIN, LOW);
  analogWrite(ENA_PIN, 0);

  delay(2000); // Pause for 2 seconds
}🔹 Applications
This component is engineered and suitable for:
- •DC motor speed regulation and soft start control
- •Robotics drive train and wheel speed adjustment
- •Cooling fans, exhaust blowers, and thermal management
- •Miniature water pumps and aquarium aeration systems
- •DIY electronics projects, automation circuits, and laboratory benches
🔹 Package Includes
- ✓1 × DC 12V 10RPM Metal Geared Motor
Wholesale Tiered Pricing
Autonomous 4WD AI & Obstacle Rover Kit
Build a complete 4-wheel drive robotics rover with ultrasonic distance sensing & motor driver control.
Related products
Complementary hardware and compatible components for your project