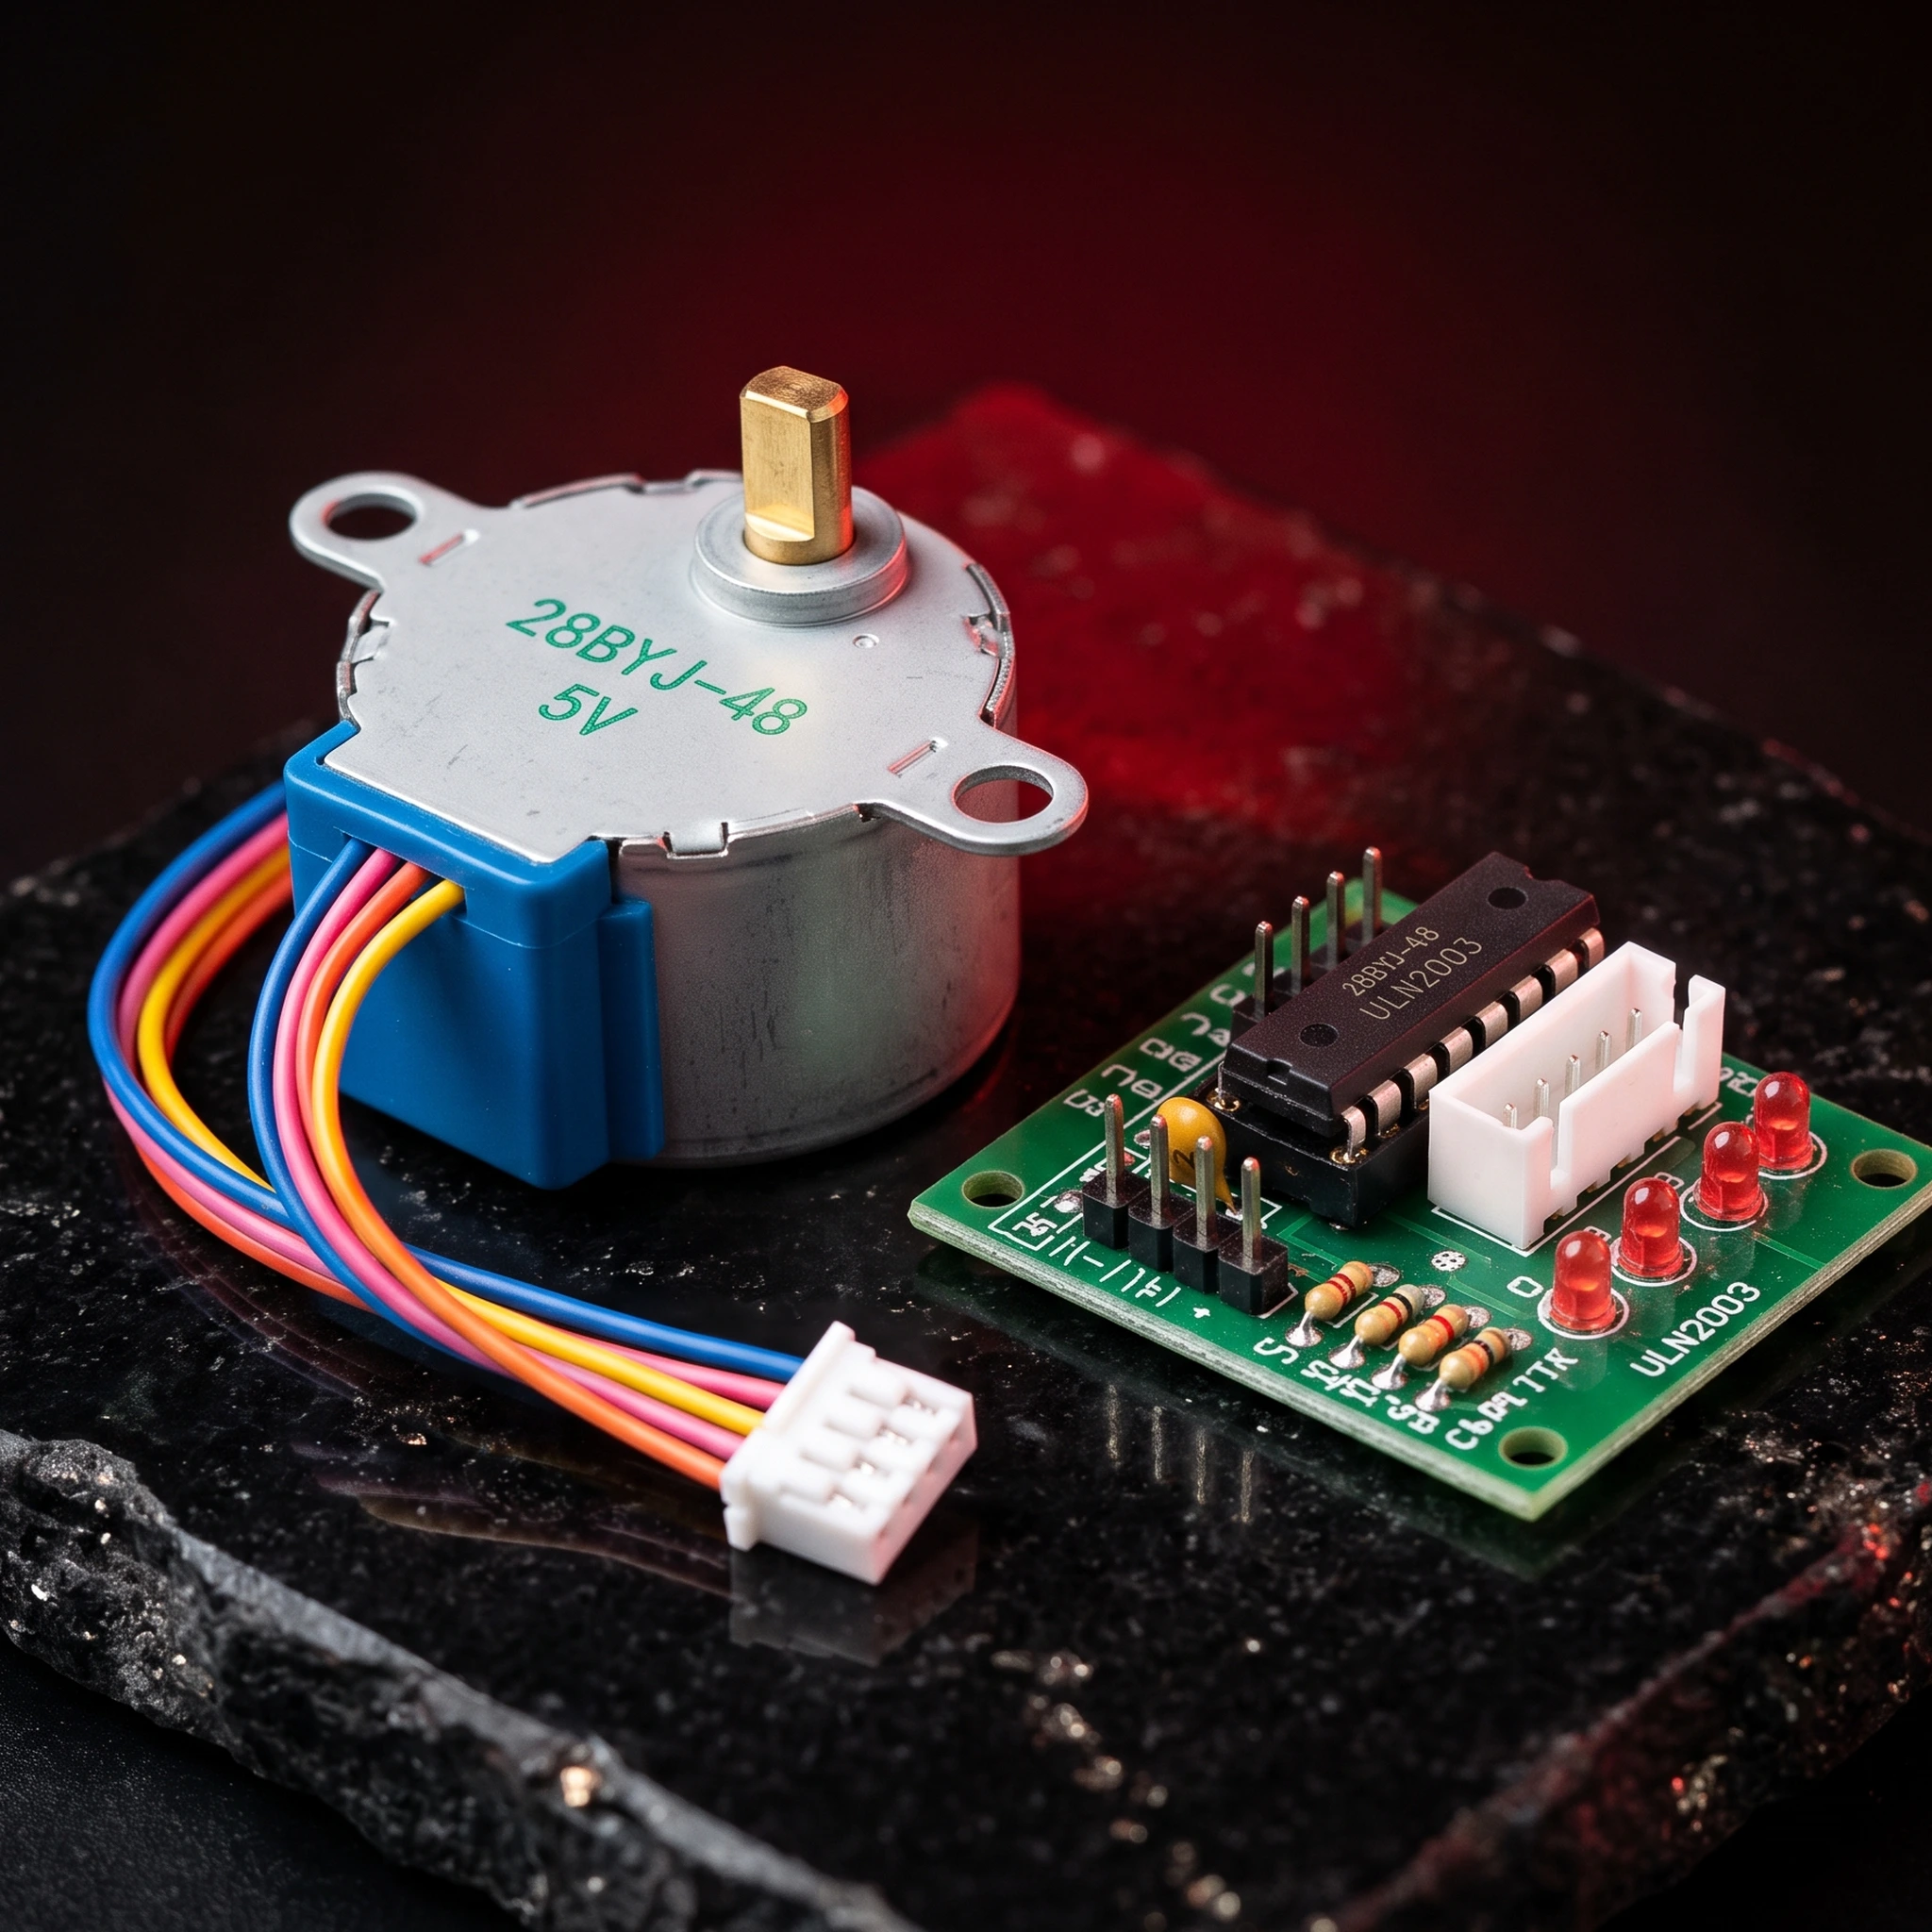
Stepper Motor(28YBJ-48) with ULN2003 Driver Board
- •Operating Voltage: 5V DC
- •This motor features a 4-phase, 5-wire configuration with an integrated reduction gearbox, delivering high torque and precise positioning at low speeds
- •The motor position is precisely controlled by simply counting the input step pulses
- •The driver board also features four LED indicators (A, B, C, D) that display the working status of each phase in real time, making testing and debugging easy
Description
The Stepper Motor(28YBJ-48) with ULN2003 Driver Board is a high-grade, precision-tested electronic component designed for reliable performance in prototyping, education, industrial control, and custom hardware engineering.
🔹 Key Features
- •This motor features a 4-phase, 5-wire configuration with an integrated reduction gearbox, delivering high torque and precise positioning at low speeds
- •The motor position is precisely controlled by simply counting the input step pulses
- •The driver board also features four LED indicators (A, B, C, D) that display the working status of each phase in real time, making testing and debugging easy
🔹 Technical Specifications
🔹 Pin Configuration & Wiring
⚠️ Direct MCU GPIO Connection Hazard
Stepper Motor(28YBJ-48) with ULN2003 Driver Board is an inductive electro-mechanical load drawing up to 200mA – 1A+ surge current. An ESP32 GPIO pin is rated for only 12mA (Arduino Uno is rated for 20mA).
Never wire this motor directly to ESP32 / Arduino pins. Doing so will immediately destroy the microcontroller's output transistors due to inrush current and reverse back-EMF inductive voltage spikes. Always use an intermediate motor driver or transistor switch with a common ground.
Recommended Driver & Interfacing Architectures
Select your interfacing method to inspect the exact wiring diagram & code
Connection Matrix
// Safe Motor & Air Pump PWM Speed Control using L298N Driver
// Tested for Arduino Uno & ESP32 (with ESP32 ledcWrite)

#define ENA_PIN 9   // Connect to L298N ENA (PWM speed control)
#define IN1_PIN 8   // Connect to L298N IN1 (Direction / ON)
#define IN2_PIN 7   // Connect to L298N IN2 (Direction / OFF)

void setup() {
  pinMode(ENA_PIN, OUTPUT);
  pinMode(IN1_PIN, OUTPUT);
  pinMode(IN2_PIN, OUTPUT);

  // Initialize driver in OFF state
  digitalWrite(IN1_PIN, LOW);
  digitalWrite(IN2_PIN, LOW);
  analogWrite(ENA_PIN, 0);
}

void loop() {
  // Soft start: ramp up speed to prevent inrush current spikes
  digitalWrite(IN1_PIN, HIGH);
  digitalWrite(IN2_PIN, LOW);

  for (int speed = 100; speed <= 255; speed += 15) {
    analogWrite(ENA_PIN, speed);
    delay(50);
  }

  delay(3000); // Run motor at full speed for 3 seconds

  // Coast to stop
  digitalWrite(IN1_PIN, LOW);
  digitalWrite(IN2_PIN, LOW);
  analogWrite(ENA_PIN, 0);

  delay(2000); // Pause for 2 seconds
}🔹 Applications
This component is engineered and suitable for:
- •DC motor speed regulation and soft start control
- •Robotics drive train and wheel speed adjustment
- •Cooling fans, exhaust blowers, and thermal management
- •Miniature water pumps and aquarium aeration systems
- •DIY electronics projects, automation circuits, and laboratory benches
🔹 Package Includes
- ✓1 × Stepper Motor(28YBJ-48) with ULN2003 Driver Board
Wholesale Tiered Pricing
Autonomous 4WD AI & Obstacle Rover Kit
Build a complete 4-wheel drive robotics rover with ultrasonic distance sensing & motor driver control.
Related products
Complementary hardware and compatible components for your project